Personal record / 2027

HUANG, Lok Hin

Wilson

Career focusEmbedded software · MCU / RTOS

Research interestRobot motion control and learning methods

Study
HKUST · Computer Engineering
Graduation
2027 (expected)
Location
Hong Kong · Shenzhen

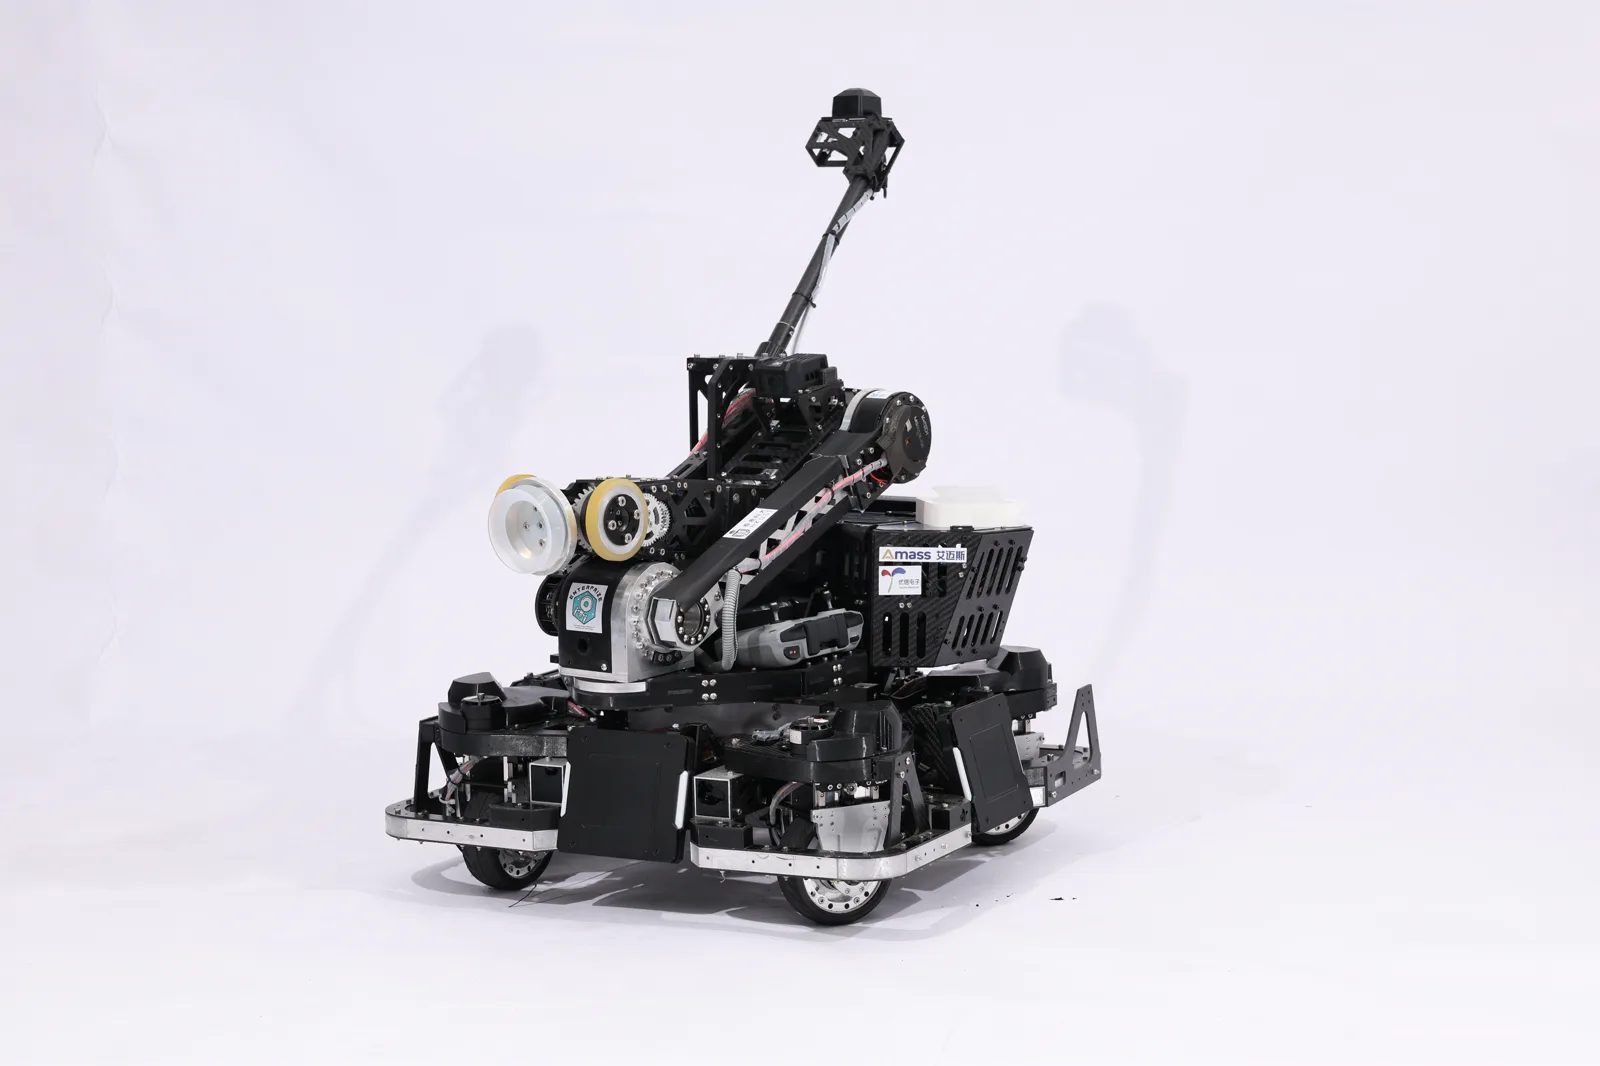
My projects span full-robot embedded control, shared firmware, manipulator modeling, chassis power control, and bipedal learning control.

HUANG, Lok Hin
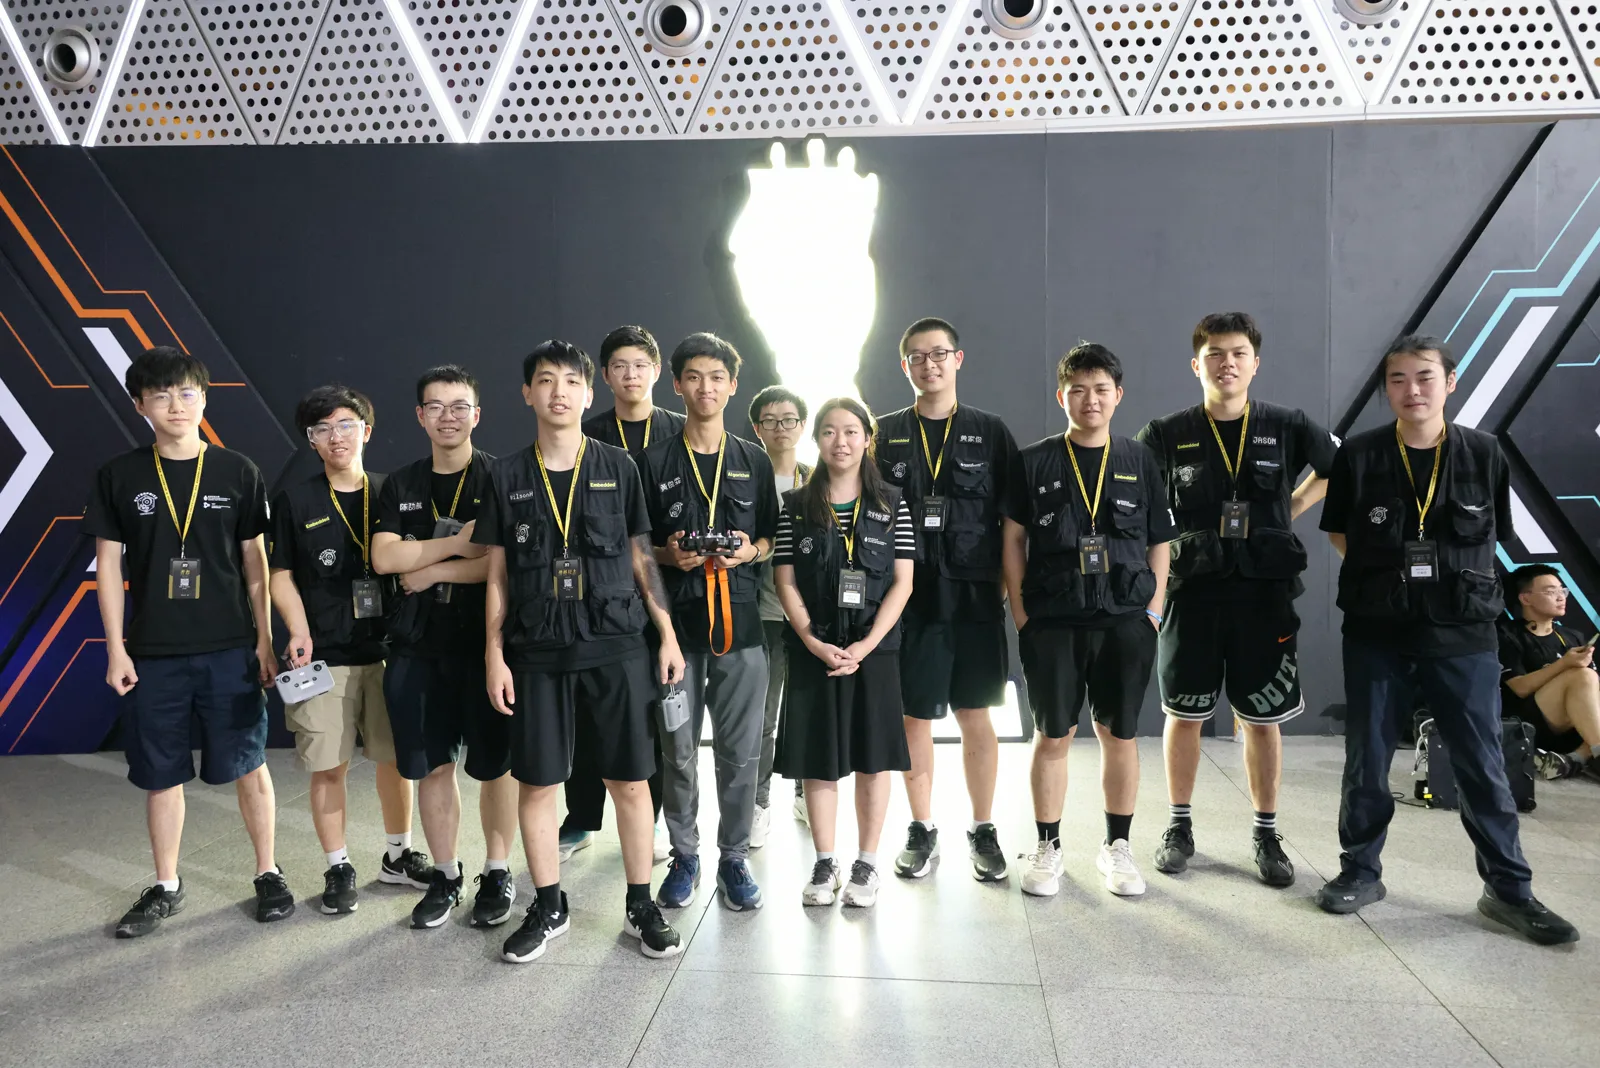
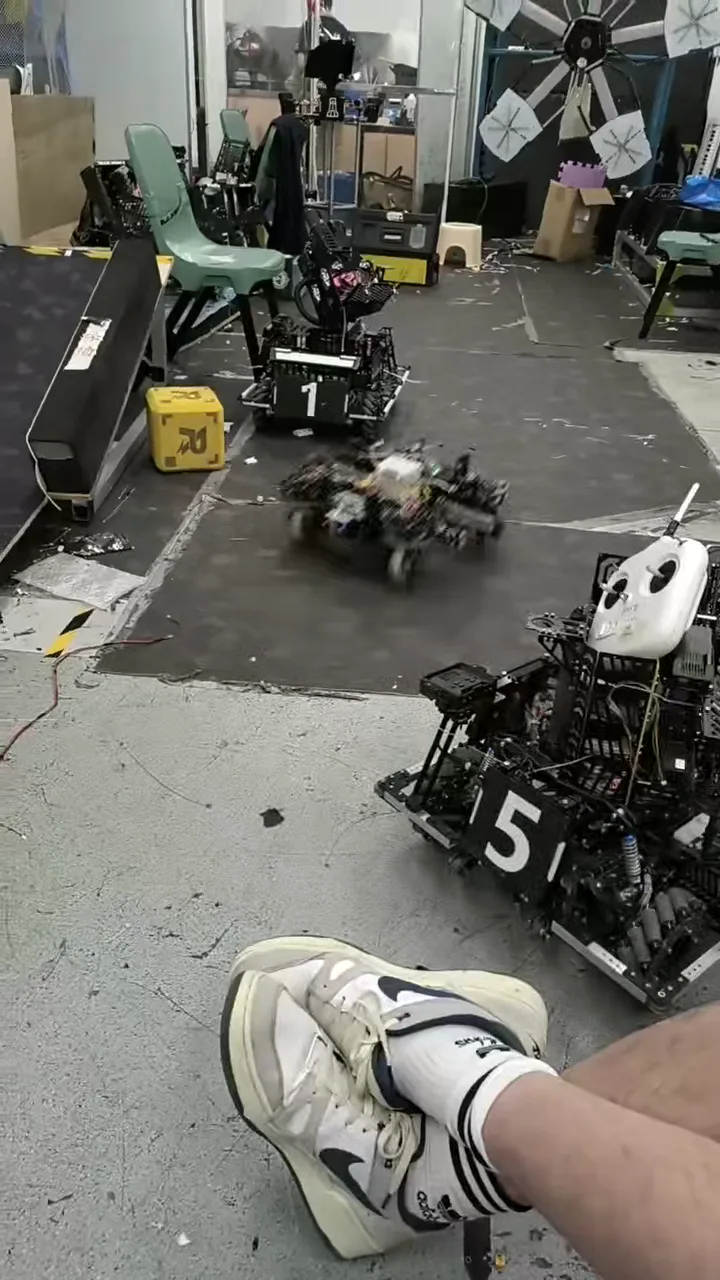
RoboMaster 2025 competition fieldRoboMaster 2025

Internship

Embedded systems internship

Motor and actuator communication, basic motion control, and system integration for outdoor intelligent vehicles.

Shenzhen

Embedded Systems Intern

Shenzhen WildNovate Technology Co., Ltd.

Key work

  • Developed UART/RS485, CAN, and PWM/PPM control links on GD32F470/GD32H737 with FreeRTOS.
  • Designed timeout detection, recovery, state reporting, and protection for communication faults, actuator disconnections, and supply fluctuations.
  • Checked communication timing with oscilloscopes and logic analyzers; communication drivers and related modules passed extended stress tests lasting about 1–2 days. Contributed to basic motion control and system integration.
  • During integration, identified priority inversion between communication and logging tasks, and prolonged blocking caused by an unreleased buffer mutex. The final approach avoided the problem through architectural changes.

Technical environment

GD32F470/H737 · FreeRTOS · UART/RS485 · CAN · PWM/PPM · Kinematics/Dynamics · Hardware Debugging
Research interests

Research interests & current work

I am interested in robot motion control and the application of learning methods, including reinforcement learning, to physical robots. My manipulator, chassis power-control, and bipedal projects inform these interests.

Final-year projectProposal

Lightweight Strut-Node Based Modular Self-Reconfigurable Robot Platform

Exploring a lightweight modular self-reconfigurable robot platform, currently at the proposal stage.

My role · Embedded systems and algorithms

Project experience

Full-robot control, shared embedded firmware, and motion control.

Selected projects

03

Team & education

Team responsibilities & education

  1. Embedded Team Lead

    HKUST ENTERPRIZE RoboMaster Team

    Led a team of about ten, assigned work, reviewed PRs, maintained shared firmware, and handled field issues. Designed and delivered about ten onboarding sessions.

  2. Hong Kong University of Science and Technology (HKUST)

    BEng in Computer Engineering · Minor in Robotics · Extended Major in Artificial Intelligence

    Completed coursework · System Modeling, Analysis and Control · Introduction to Embedded Systems · Machine Learning · Design and Analysis of Algorithms

    Current coursework · Reinforcement Learning · Robotics: Modeling, Control and Planning

About me

I first encountered RoboMaster at the team’s recruiting booth during my freshman year, which led me into embedded systems and robotics control. With unfamiliar problems, I prefer to break them down, research, and test independently first; when I reach the edge of my experience, I ask senior teammates with the approaches I have already tried. Later, as embedded team lead, I began passing that experience on through training, code review, and everyday discussions with junior members.

Frequent tools and technologies

C/C++ · ARM Cortex-M · STM32/GD32 · FreeRTOS · CAN/FDCAN · UART/SPI/I2C/Modbus · DMA/Interrupts · Motor/Actuator Control · PID · State Machines · Kinematics/Dynamics · Python · KiCad · Schematics · Oscilloscope · Logic Analyzer · SystemView · Tracealyzer · Git

Languages

Mandarin · Cantonese · English (Fluent)

Contact

Contact & résumés

I welcome conversations about embedded software roles, robotics projects, and research master’s opportunities.